

Noise and Decoherence in Metrology
Noise in quantum metrology is any uncontrolled or incompletely modeled part of a sensing experiment that changes the distribution of recorded data. It may enter during state preparation, parameter encoding, control, storage, transport, or readout. Decoherence is narrower: it is the loss of off-diagonal coherence in a specified reduced description after degrees of freedom or records are ignored. Dephasing, energy relaxation, particle loss, detector errors, calibration drift, and common-mode fluctuations can all limit a sensor, but they are not interchangeable mechanisms.
The metrological question is also more precise than “how much coherence survives?” A useful sensor must keep states corresponding to nearby parameter values distinguishable, deliver that distinguishability through an available measurement, and do so at a favorable rate after every probe, second, calibration, and failed trial is counted. A channel may destroy one kind of coherence while preserving the signal, or preserve a beautiful state while erasing the derivative that carried the signal.
The central examples below compare product and GHZ probes under dephasing, optical probes under loss, and protected modes under correlated noise. Their different outcomes explain why a statement about noise must specify the encoding, controls, and available records.
Required background. Quantum Measurement as Estimation supplies likelihoods and nuisance parameters; Classical and Quantum Fisher Information supplies QFI and its measurement bound; Cramér–Rao Bounds explains local precision and attainability; Quantum Channels and Noise introduces Kraus and master-equation descriptions.
Parameter encoding through a noisy channel
Section titled “Parameter encoding through a noisy channel”Write one controlled use of a sensor as a parameterized channel
followed by a POVM . The controls include preparation, interrogation time, pulse sequence, ancillary systems, and measurement setting. The nuisance vector may include dephasing rates, loss, contrast, detuning drift, temperature, and calibration coefficients. The actual likelihood is
This formula prevents several common category errors. Noise is not an additive scalar attached after an ideal sensitivity calculation. It changes the state family, and therefore changes its derivatives, optimal measurement, likelihood support, nuisance correlations, and sometimes the meaning of a resource.
The parameter may enter a Hamiltonian, a decay rate, or a bath state. Ancillas, control, observed environment records, and the fixed resource (time, energy, or channel uses) therefore matter. “Noise restores the SQL” is a theorem only for a specified channel family and allowed operations.
Information in the recorded measurement
Section titled “Information in the recorded measurement”For one completed cycle, an implemented measurement has classical Fisher information , bounded by the quantum Fisher information of the output state:
If cycles are independent and identically configured, a locally unbiased estimator obeys
The output QFI is independent of the chosen measurement, but relies on the specified state and channel model; it is not device-independent certification. It does not promise that the available readout attains the corresponding precision. Noise can rotate the optimal measurement with the unknown parameter, make nuisance parameters nearly degenerate with the signal, or leave information in an inaccessible environment.
Data processing, with an important qualification
Section titled “Data processing, with an important qualification”If a parameter-independent channel acts after encoding, QFI is contractive:
Discarding a subsystem, adding parameter-independent detector noise, or coarse-graining a record cannot increase the available information. But the qualification matters: when itself depends on the unknown parameter, it can encode information. Thermometry, loss estimation, noise spectroscopy, and estimation of a decay rate use the “noise” as the signal. Contractivity does not compare different parameter-dependent channel families.
Information rate and dead time
Section titled “Information rate and dead time”Suppose an interrogation lasts , while preparation, reset, readout, and feedback require dead time . The cycle time is
so a long run of duration contains approximately cycles. The relevant local objective is then
Longer interrogation usually increases signal phase but decreases contrast and the number of repetitions. Maximizing per-shot QFI can therefore select a different operating point from maximizing precision per unit wall-clock time.
Physically different noise mechanisms
Section titled “Physically different noise mechanisms”| Distinction | First diagnostic | Metrological consequence |
|---|---|---|
| dephasing vs dissipation | are basis populations preserved? | phase contrast and energy response degrade differently |
| erasure vs unflagged loss | is the missing probe identified? | a flagged event can enter the likelihood rather than disappear |
| independent vs correlated noise | how does covariance scale across probes? | information may remain extensive, saturate, or occupy a protected differential mode |
| semigroup vs time-inhomogeneous dynamics | does hold? | short-time behavior can change asymptotic frequency scaling |
| unmonitored vs monitored environment | are jump, leakage, or bath records observed? | discarded records can contain recoverable information |
| known vs unknown noise parameters | are rates and contrasts calibrated? | nuisance correlations reduce effective signal information |
| signal-parallel vs signal-transverse noise | does control suppress both by the same symmetry? | decoupling or correction may preserve the signal, or erase it |
For the dynamical distinctions behind the first row, see Dephasing vs Dissipation. For the precise hierarchy of non-Markovian definitions, see What Non-Markovian Means.
Exact Qubit Dephasing Example
Section titled “Exact Qubit Dephasing Example”Consider a Ramsey qubit initialized in , accumulating an unknown angular frequency for time . Let a real coherence envelope describe parameter-independent dephasing. Immediately before the final analysis pulse,
The QFI for phase is , and the frequency QFI is
A quadrature Ramsey measurement attains this local value when its analysis phase is correctly set. For independent probes in the same cycle,
Thus dephasing reduces the information by the square of the surviving coherence in this model. That compact result is not universal: amplitude damping changes populations as well as coherence, and parameter-dependent noise adds derivative terms of its own. The Dephasing Channel page gives the channel and Kraus representations.
Markovian dephasing and the optimal time
Section titled “Markovian dephasing and the optimal time”For exponential coherence
and negligible dead time, the product-state information rate is
Its optimum occurs at
Now prepare the -qubit GHZ state. The signal phase is amplified to , but independent dephasing multiplies its one fragile coherence by . Its per-cycle QFI and rate are
The optimum moves to
The -fold faster phase accumulation is exactly canceled by an -fold shorter useful interrogation. In this idealized model the optimized GHZ and product strategies have the same information rate. State-preparation time, collective readout error, and nonzero dead time generally make the maximally entangled strategy less favorable, while partially entangled or squeezed states can still improve finite-resource constants in broader models.
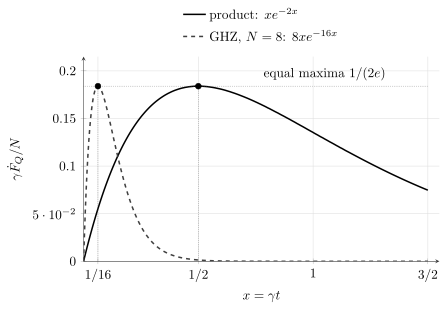
With coherence and zero dead time, product probes have , while an GHZ probe has . The optimal times differ by eight, but both curves reach . The result compares frequency information per total time, not phase information in a single shot.
Dead time changes the optimization
Section titled “Dead time changes the optimization”For exponential decay with coefficient in the exponent, maximizing
gives the positive stationary point
Use for product probes and for GHZ probes, together with their different prefactors. A short GHZ interrogation pays the fixed overhead many more times. In clock language, dead time can also alias local oscillator noise into the measurement band; that system effect is not captured by the simple independent-cycle formula.
Readout contrast is another channel
Section titled “Readout contrast is another channel”If a symmetric binary readout has net contrast and is operated at quadrature, its local Fisher information becomes
The factors and may look identical in one fringe, but they arise at different stages and respond differently to controls. A calibration that treats as known can overstate precision if contrast drift is correlated with frequency. The multiparameter Fisher matrix, not a scalar contrast correction, is then required.
Photon Loss and Fragile Optical States
Section titled “Photon Loss and Fragile Optical States”Loss couples the sensed optical mode to inaccessible modes. It reduces detected energy, leaks which-path information, and turns pure inputs into mixed states. It must be placed at a declared reference plane: source loss, propagation loss, sample absorption, collection loss, and detector inefficiency are physically different even when they share a transmissivity.
Consider a two-arm interferometer with differential-phase encoding , independent loss of the same fixed transmissivity in both arms, and inaccessible loss environments. Let count the total incident photons in both arms. The channel bound (Demkowicz-Dobrzański, Jarzyna, and Kołodyński) gives
Here is a local Cramér–Rao precision benchmark; for independent repetitions, the total incident energy is counted. A single lossy mode with generator , a lossless external phase reference, and signal photons instead has the bound . The factor cannot be selected without specifying the generator and reference. In both cases, fixed independent loss limits the asymptotic QFI to linear growth with the stated energy. Entanglement and squeezing may still improve the constant, sometimes substantially, but do not restore asymptotic QFI.
The bound becomes loose as and should not be used as a finite- interpolation formula. It also does not apply unchanged to heralded erasure, correlated loss, monitored environments, nonlinear sample interactions, or a different resource definition.
Why NOON coherence is fragile
Section titled “Why NOON coherence is fragile”For the equal-arm loss model above, an -photon NOON state retains its phase-sensitive coherence only when every photon survives. That block has weight , and all lost-photon blocks carry no differential phase. The unconditional output QFI is exactly
The ideal sensitivity is eventually overwhelmed by exponential loss. Optimal lossy probes distribute number more gently than a NOON state, and coherent light mixed with squeezed vacuum can approach the relevant large-energy bound in important interferometric regimes. The lesson is not that nonclassical light is useless; it is that the most fragile noiseless optimum is rarely the noisy optimum. See Mach–Zehnder Interferometry for optical probe and measurement details.
Incident, interacting, and detected resources
Section titled “Incident, interacting, and detected resources”Three photon numbers should not be silently identified:
A photosensitive sample may make the scarce resource, while a remote-sensing link may be limited by transmitted energy and aperture. Detector loss can sometimes be improved without increasing sample exposure. Every quantum and classical comparator must use the same resource boundary.
General Bounds from Channel Geometry
Section titled “General Bounds from Channel Geometry”For independent uses of a parameterized channel, bounds can be formulated without optimizing over an exponentially large input state. Let be Kraus operators and dots denote derivatives. Define, for a chosen Kraus representation,
Kraus representations are not unique. A parameter-dependent unitary rotation on the environment changes and without changing the channel. Optimizing over this freedom gives a channel-extension bound of the form
Here generates the Kraus-space rotation and is the operator norm. If a representation can be chosen with and bounded , the quadratic term vanishes:
That establishes at-most-linear asymptotic QFI for the specified independent channel, even allowing entangled probes and passive ancillas. It does not say that every measurement attains the bound, and it does not automatically cover correlated channels, adaptive memory effects, or a control model outside the derivation.
These bounds explain why weak local dephasing, depolarization, relaxation, or loss often changes the large- result discontinuously: ideal quadratic QFI can persist over a finite preasymptotic region, yet the true asymptote is linear. A handful of small- data points cannot distinguish a long crossover from a new scaling law.
Short-Time Dynamics and the Zeno Scaling
Section titled “Short-Time Dynamics and the Zeno Scaling”Exponential decay at arbitrarily short times is an idealization. Many microscopic models begin quadratically. Suppose independent dephasing has
Assume , independent noise across probes, and independent repetitions (for example, with an appropriate bath reset). For an -qubit GHZ state at short times,
and, neglecting dead time, its information rate scales as
Optimization gives
At fixed total time the variance can therefore scale as . For quadratic short-time decay, , this is the Zeno scaling
This improvement is neither the noiseless Heisenberg law nor a generic reward for “non-Markovianity.” The decisive assumption is the short-time departure from a semigroup, together with access to interrogation times that shrink into that regime and repeated data with the assumed independence. Resetting a probe alone need not reset a slowly fluctuating environment. Finite control bandwidth, dead time, spatial correlations, and a later exponential regime can remove the asymptotic window. Information backflow is one possible feature of memory, but it is not the criterion behind the bound above (Smirne and colleagues).
For example, if a fixed nonzero dead time dominates the shrinking interrogation, the same GHZ calculation instead maximizes . It gives and rate . For quadratic decay this is linear in , so the zero-dead-time rate does not survive this limit.
Correlated Noise Can Saturate or Protect
Section titled “Correlated Noise Can Saturate or Protect”Correlations change which collective mode contains signal and which contains noise. A classical Gaussian example already shows the geometry. Let one simultaneous sensor record be
For known, positive-definite, parameter-independent , its Fisher information is
For a common signal and covariance
the result is
Independent noise alone gives information proportional to . Any fixed common-mode component makes the information saturate at as . Treating the records as independent would report fictitious precision.
Conversely, a differential signal vector satisfying lies outside the common-noise mode. A differential estimator or decoherence-free subspace can reject that noise. But it also rejects any signal with the same common-mode symmetry. Protection is possible when signal and noise occupy distinguishable operator or spatial subspaces, not merely because noise is correlated. Distributed Quantum Sensing develops this geometry for sensor networks and entangled probes.
Noise Parameters as Nuisance Parameters
Section titled “Noise Parameters as Nuisance Parameters”Suppose the signal is estimated jointly with unknown contrast, dephasing, or drift parameters . Partition the Fisher matrix as
For a regular, jointly identifiable model with invertible , the effective local information for is the Schur complement
A singular nuisance block requires restriction to identifiable directions and an explicit check that the desired signal can be estimated; an arbitrary matrix inverse or prior cannot supply missing data. If the signal derivative resembles a contrast or drift derivative, can be much smaller than . Separate calibration data add information to , but the associated probes and time belong in an end-to-end resource comparison. A prior can regularize weakly identified nuisance directions, but then the reported bound is Bayesian and prior-dependent.
When decoherence is the signal
Section titled “When decoherence is the signal”For the dephasing qubit above with and known phase, the QFI for the decay rate is
The channel now encodes through the Bloch-vector length. Noise spectroscopy and relaxometry exploit this dependence. Calling decoherence purely detrimental would miss the parameter being measured.
Control Is a Signal-and-Noise Filter
Section titled “Control Is a Signal-and-Noise Filter”A control sequence changes both the signal and noise couplings. For a qubit with toggling-frame Hamiltonian , take in angular-frequency units. The target phase is
For zero-mean stationary classical Gaussian noise, define the two-sided angular-frequency spectrum and filter by
The random phase is . Its Gaussian characteristic function gives coherence , where
The factor is essential: phase variance and the coherence-decay exponent are different quantities. Other spectral conventions redistribute factors of or , so the spectrum and filter must be defined together.
The same modulation determines both signal response and noise filter. Spin echo suppresses quasistatic detuning, but it also cancels a static signal coupled through the same operator. For AC sensing, pulse timing can make the target add coherently while low-frequency drift cancels. Dynamical Decoupling derives filter functions and explains sequence limitations.
Useful control strategies include:
- choosing a clock transition or sweet spot with small nuisance derivative;
- common-mode rejection and differential encoding;
- dynamical decoupling matched to a target waveform;
- adaptive interrogation times that balance range and coherence;
- optimal control that shapes both signal generator and dissipation;
- reservoir engineering or autonomous stabilization;
- monitoring emitted quanta or leakage flags when their records are informative;
- quantum error detection or correction when signal and error actions can be separated.
Every strategy has overhead and bandwidth. Pulse errors, finite duration, ancilla dephasing, recovery latency, and calibration drift belong in the implemented channel, not in a footnote after the ideal result.
Environment Monitoring and Conditional Records
Section titled “Environment Monitoring and Conditional Records”An unconditional master equation averages over possible environment records. If emitted photons, quantum jumps, erasures, or ancilla syndromes are observed, the full record can retain more information than the averaged sensor state. Schematically,
Keeping the classical label produces a classical-quantum state whose QFI is
Discarding cannot increase information. This identity explains why trajectory monitoring, heralded erasure, and syndrome records can outperform an unmonitored reduced-state protocol. It also gives the correct accounting for postselection: a high-information successful branch is weighted by its success probability, and parameter-dependent success itself carries classical information. Quantum Trajectories develops conditional states and monitored records.
Quantum Error-Corrected Sensing
Section titled “Quantum Error-Corrected Sensing”Ordinary quantum error correction protects an unknown logical state. In metrology, recovery must do something subtler: suppress the dominant errors while preserving a nontrivial logical action of the signal Hamiltonian. Correcting the operator that generates the signal can make a perfectly stable but perfectly insensitive sensor.
Consider a finite-dimensional Markovian model
Define the real Lindblad span
where and . Under the strong assumptions of noiseless ancillas and arbitrarily fast, accurate control and recovery, Heisenberg scaling in total sensing time is attainable if and only if
This is the Hamiltonian-not-in-Lindblad-span, or HNLS, condition.
Two one-qubit geometries
Section titled “Two one-qubit geometries”If both signal and dephasing act through ,
then . Any code that makes errors logically invisible also removes the DC signal at leading order. Fast ideal QEC cannot restore Heisenberg scaling for that model.
This choice of gives coherence decay , matching the Ramsey convention above. If instead with the same , then . With a noiseless ancilla, the codewords
send a sensor error outside the code space, while acts as a logical signal. Frequent syndrome extraction can in principle suppress the noise without erasing the signal.
The theorem is not an off-the-shelf hardware guarantee. Real ancillas are noisy; recoveries consume time; controls have finite strength; higher-order errors accumulate; and syndrome measurements can introduce bias. A useful experiment must compare the corrected sensor with the best uncorrected and classical strategies at the same elapsed time, sensing volume, signal exposure, bandwidth, and hardware inventory. Why Quantum Error Correction Is Possible explains the Knill–Laflamme condition and general recovery theory.
Worked precision comparisons
Section titled “Worked precision comparisons”Markovian Ramsey sensor
Section titled “Markovian Ramsey sensor”Take independent qubits, coherence rate , total averaging time , and negligible dead time. The optimal product interrogation is
The total QFI ceiling is
so
An ideal 100-qubit GHZ probe uses and has the same total-QFI ceiling. It requires one hundred times as many preparation and readout cycles. Even a small fixed overhead therefore breaks the formal tie against it.
Lossy optical phase
Section titled “Lossy optical phase”For equal loss in both arms, let and count total incident photons. The channel bound gives
A coherent-state shot-noise scale based on the detected mean is approximately . Thus this particular ultimate bound allows at most a factor improvement in standard deviation over that benchmark. It does not prove that a realizable source and receiver attain the factor.
Common-mode floor
Section titled “Common-mode floor”Set and in the correlated Gaussian model. For sensors,
rather than the independently modeled value . For , , already near the asymptotic ceiling . Adding sensors cannot average away the shared fluctuation.
A longer coherence time or a larger modeled QFI does not by itself establish better measured precision. The useful checks are the implemented likelihood, its signal response, the complete record including failures, and elapsed time. Keep the chronological data when testing drift; pooling correlated cycles as independent observations can create an apparent gain.
Exercises
Section titled “Exercises”Exercise 1: QFI of a dephased Ramsey qubit
Section titled “Exercise 1: QFI of a dephased Ramsey qubit”For
with parameter-independent , use the qubit Bloch-vector formula
to derive the phase and frequency QFIs.
Solution
The Bloch vector is
so
Therefore and . Hence
For , the chain rule gives
Exercise 2: A Kraus bound for phase dephasing
Section titled “Exercise 2: A Kraus bound for phase dephasing”Take , , , and phase-channel Kraus operators and . At , rotate them by with and . Show that the resulting channel-extension bound is linear in the number of parallel uses.
Solution
The rotated derivatives are
where denotes the off-diagonal matrix element. Thus , while
The bound is therefore . For fixed it excludes asymptotic growth for this parallel phase-channel model, including passive ancillas. It need not be tight at finite and diverges as . In frequency sensing and , choosing an -dependent interrogation time requires optimizing the resulting time-dependent bound anew.
Exercise 3: Optimal interrogation with dead time
Section titled “Exercise 3: Optimal interrogation with dead time”Maximize
for and . Check the limit.
Solution
For , logarithmic differentiation gives
Setting this to zero and clearing denominators gives
The positive root is
At , this reduces to . The other quadratic root is nonpositive and is not an interrogation time.
Exercise 4: Loss bound and maximum allowed gain
Section titled “Exercise 4: Loss bound and maximum allowed gain”For equal transmissivity in both arms and total incident mean photon number , evaluate the channel loss bound. Compare it with the detected-photon coherent scale .
Solution
The loss bound is
The coherent scale is
The bound therefore allows at most a factor of two reduction in standard deviation relative to this benchmark, equal to . It is an allowed ceiling, not an achieved protocol.
Exercise 5: Common-mode Fisher information
Section titled “Exercise 5: Common-mode Fisher information”Use the Sherman–Morrison identity to invert
and derive .
Solution
The rank-one inverse is
Using gives
Exercise 6: Does the code preserve the signal?
Section titled “Exercise 6: Does the code preserve the signal?”For codewords
show that a sensor error is detectable and that the signal acts nontrivially within the code.
Solution
Since and ,
Both states are orthogonal to both codewords, so and the error can be detected without learning the logical amplitude. Meanwhile,
Thus is a nontrivial logical generator. The code separates the transverse signal from the dephasing error in the ideal model.
Exercise 7: Postselection accounting
Section titled “Exercise 7: Postselection accounting”A protocol succeeds with parameter-independent probability . Its successful records have Fisher information ; failures are discarded and carry no parameter information. What is the information per attempted trial? How does the answer change conceptually if ?
Solution
For parameter-independent success, the complete-record Fisher information is
Reporting per attempt would overstate the information by a factor of ten. If depends on , the success/failure label contributes binary Fisher information
and the conditional successful and failed branches must also be weighted by their probabilities. Discarding the failure label can introduce both lost information and selection bias.
Exercise 8: Derive the decay-rate QFI
Section titled “Exercise 8: Derive the decay-rate QFI”For a qubit with Bloch vector and , derive the QFI for and inspect its short-time limit.
Solution
The derivative is
The derivative is parallel to , so the qubit Bloch formula gives
For , , so
The information per shot tends to zero even though the state approaches a pure state and the Bloch-radius derivative is measured relative to a small mixedness. Decoherence is the parameter-encoding mechanism in this task.
References
Section titled “References”-
A. W. Chin, S. F. Huelga, and M. B. Plenio, “Quantum metrology in non-Markovian environments,” Physical Review Letters 109, 233601 (2012), doi:10.1103/PhysRevLett.109.233601.
-
R. Demkowicz-Dobrzański, J. Czajkowski, and P. Sekatski, “Adaptive quantum metrology under general Markovian noise,” Physical Review X 7, 041009 (2017), doi:10.1103/PhysRevX.7.041009.
-
R. Demkowicz-Dobrzański, J. Kołodyński, and M. Guţă, “The elusive Heisenberg limit in quantum-enhanced metrology,” Nature Communications 3, 1063 (2012), doi:10.1038/ncomms2067.
-
R. Demkowicz-Dobrzański, M. Jarzyna, and J. Kołodyński, “Quantum limits in optical interferometry,” Progress in Optics 60, 345–435 (2015), doi:10.1016/bs.po.2015.02.003.
-
B. M. Escher, R. L. de Matos Filho, and L. Davidovich, “General framework for estimating the ultimate precision limit in noisy quantum-enhanced metrology,” Nature Physics 7, 406–411 (2011), doi:10.1038/nphys1958.
-
S. F. Huelga et al., “Improvement of frequency standards with quantum entanglement,” Physical Review Letters 79, 3865–3868 (1997), doi:10.1103/PhysRevLett.79.3865.
-
J. Kołodyński and R. Demkowicz-Dobrzański, “Efficient tools for quantum metrology with uncorrelated noise,” New Journal of Physics 15, 073043 (2013), doi:10.1088/1367-2630/15/7/073043.
-
K. Macieszczak, “Zeno limit in frequency estimation with non-Markovian environments,” Physical Review A 92, 010102(R) (2015), doi:10.1103/PhysRevA.92.010102.
-
P. Sekatski, M. Skotiniotis, J. Kołodyński, and W. Dür, “Quantum metrology with full and fast quantum control,” Quantum 1, 27 (2017), doi:10.22331/q-2017-09-06-27.
-
A. Smirne, J. Kołodyński, S. F. Huelga, and R. Demkowicz-Dobrzański, “Ultimate precision limits for noisy frequency estimation,” Physical Review Letters 116, 120801 (2016), doi:10.1103/PhysRevLett.116.120801.
-
S. Zhou, M. Zhang, J. Preskill, and L. Jiang, “Achieving the Heisenberg limit in quantum metrology using quantum error correction,” Nature Communications 9, 78 (2018), doi:10.1038/s41467-017-02510-3.