

Classical and Quantum Fisher Information
Fisher information quantifies how quickly nearby parameter values become statistically distinguishable. In a quantum experiment there are two distinct levels:
- classical Fisher information belongs to the outcome distribution produced by a specified measurement;
- quantum Fisher information is the greatest classical Fisher information available from the parameterized quantum state when all POVMs on that state are considered.
That distinction is operational. A state may contain information that the implemented detector does not extract. Conversely, a reported does not identify a realizable detector, remove nuisance parameters, resolve global aliases, or guarantee good finite-sample performance.
The following derivation connects the likelihood to the SLD, works through qubit examples, and explains the qualifications at rank changes and in multiparameter estimation.
Required background. Use classical Fisher information for scores and regularity assumptions, POVMs for outcome probabilities, and density operators for spectra and mixtures.
The measured probability distribution
Section titled “The measured probability distribution”Let a real parameter be encoded in a density operator . A parameter-independent POVM
produces the probabilities
For discrete outcomes, the classical Fisher information of this measurement is
For a continuous record, replace the sum by an integral with respect to the declared reference measure. Outcomes whose probability vanishes require a limit or a support-sensitive treatment; silently inserting into the fraction is not meaningful.
The notation deliberately names the measurement. Changing the basis, detector resolution, acceptance rule, or coarse graining changes the likelihood and can change the available information.
Classical Fisher Information After Measurement
Section titled “Classical Fisher Information After Measurement”The score of one observed outcome is
Under the usual regularity assumptions, , and
Thus is a local signal-to-noise ratio for the score. If changes the probabilities strongly compared with their statistical fluctuations, is large. If all probabilities are positive and locally stationary, for that measurement even when another measurement would be informative. Zero-probability outcomes require the separate support analysis noted above.
For independent repetitions of the same measurement,
This additivity is a statement about independent likelihoods, not about every experiment containing nominal shots. Drift, temporal correlations, adaptive settings, dead time, and postselection must be represented in the actual joint likelihood.
Classical postprocessing cannot increase Fisher information. If is generated from by a parameter-independent stochastic map , then
Discarding time tags, binning a continuous signal too coarsely, thresholding an analog record, or merging detector outcomes may therefore lose sensitivity.
Quantum Fisher Information as an Optimization
Section titled “Quantum Fisher Information as an Optimization”For a one-parameter state family, the SLD quantum Fisher information is
where the supremum is over parameter-independent POVMs on the system at the specified operating point. In a regular finite-dimensional one-parameter model, this supremum is attained locally by a projective measurement in an eigenbasis of the SLD defined below.
The optimization has three important qualifications:
- It is local in . It compares infinitesimally neighboring states, not all parameter values across a wide prior interval.
- The optimizing measurement can depend on the unknown true value. Practical protocols use prior localization, adaptive measurements, covariant constructions, or a detector that is near-optimal over a declared range.
- The optimization must respect the physical measurement class. If only a restricted set is implementable, the relevant quantity is
which may be strictly smaller than .
Symmetric Logarithmic Derivative
Section titled “Symmetric Logarithmic Derivative”The symmetric logarithmic derivative is a Hermitian operator satisfying
The corresponding quantum Fisher information is
If is not full rank, need not be unique on the kernel of . Its action on the support determines , so this nonuniqueness does not change the value in a regular fixed-rank model. Points where rank or support changes deserve separate care: the SLD expression, its nearby limit, and finite-difference distinguishability need not behave as a naive smooth formula suggests.
The SLD is not usually an observable that the parameter encoding literally couples to. It is the locally optimal score operator for the quantum model.
Why Every Measurement Obeys the Quantum Bound
Section titled “Why Every Measurement Obeys the Quantum Bound”For a fixed POVM element ,
A Hilbert–Schmidt Cauchy–Schwarz inequality gives
Summing over outcomes yields the Braunstein–Caves inequality,
At a known operating point, measuring the spectral projectors of saturates the scalar bound under the regularity conditions. This proves a local optimization statement. It does not prove that one fixed detector is globally optimal or that the resulting estimator reaches a variance bound for a finite data set.
Spectral Formula for Mixed States
Section titled “Spectral Formula for Mixed States”Write the spectral decomposition
In this instantaneous eigenbasis, the SLD matrix elements on the support are
Therefore
Separating eigenvalue and eigenvector changes gives
The first line is information in changing eigenvalues and is classical in the instantaneous eigenbasis. The second is information in rotating eigenvectors, which requires a measurement sensitive to coherence between those directions.
For a commuting family,
one common eigenbasis measures all the available information, and reduces to the classical Fisher information of the eigenvalues.
Pure-State Formula
Section titled “Pure-State Formula”For a differentiable normalized state , write
The pure-state quantum Fisher information is
The subtraction removes parameter-dependent global phase. If , the ray does not change and .
For a unitary encoding
with a parameter-independent Hermitian generator and dimensionless phase ,
This identity is exact for pure states. For a mixed input under the same unitary encoding,
and only the inequality
holds in general. A mixed state can have nonzero generator variance entirely from classical uncertainty while commuting with ; then the state does not move under the encoding and its QFI is zero.
Example: A Qubit Phase
Section titled “Example: A Qubit Phase”Consider
Direct substitution into the pure-state formula gives
At a provisional operating point , measure the observable
Its two outcome probabilities are
At ,
The detector is locally optimal because it measures the quadrature with the largest slope at the operating point. But the state and likelihood are periodic, so alone cannot identify which branch contains the true phase. Dynamic range and phase unwrapping belong to the full estimation protocol.
Example: A Commuting Qubit Family
Section titled “Example: A Commuting Qubit Family”Let
Only the eigenvalues change. Measuring in the computational basis gives a Bernoulli model and
The spectral QFI formula gives the same result, so
No coherent measurement is needed because the model is already classical in a common basis. The divergence near or is also a warning: boundary points violate some regularity assumptions behind familiar local asymptotic conclusions.
Example: Dephased Phase Sensing
Section titled “Example: Dephased Phase Sensing”An equatorial qubit with reduced coherence can be written
Its Bloch vector has constant length and rotates in the equatorial plane. The qubit formula derived below gives
If the unknown parameter is a frequency , the phase is , and Markovian dephasing gives , then one interrogation has
Ignoring dead time, a total duration permits about independent interrogations, so
For and many repetitions, with large compared with the candidate interrogation time, this continuous-time approximation is maximized at . A finite experiment also imposes and an integer shot count. Longer coherent evolution increases the phase slope but also destroys contrast. The useful optimization variable is therefore not state QFI in isolation, but total information under the declared time and noise model.
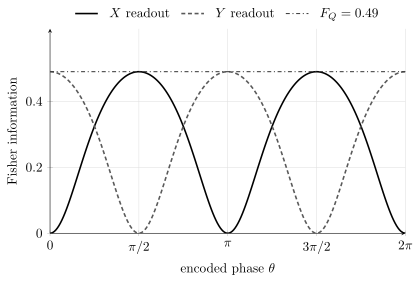
For fixed contrast , the encoded state has . An measurement attains this at ; a measurement attains it at . At the intervening extrema of its own probability curve each detector is locally insensitive. Changing the measurement basis recovers the information; it does not increase the state’s QFI.
Bloch-Vector Formula
Section titled “Bloch-Vector Formula”For a full-rank qubit
write . Using the Pauli anticommutator in the SLD equation gives
Thus and . Substitution into gives
The first term measures motion of the Bloch vector. The second records changes in its length, weighted more strongly near the pure-state boundary. For a smooth path that stays pure, and ; taking the appropriate tangent limit gives
One should not substitute directly into the full-rank formula. The apparent is the coordinate trace of a rank boundary.
Geometry of Neighboring States
Section titled “Geometry of Neighboring States”Define the squared Uhlmann fidelity by
and the Bures distance by
For a smooth family of constant rank in a neighborhood, these conventions give
Thus QFI is four times the Bures metric on a regular state manifold. At a rank-changing point the equality can fail: the Bures distance can detect second-order population changes that the SLD at that point misses. Exercise 9 gives an explicit example; see Šafránek (2017).
For pure states, the Bures metric reduces locally to the Fubini–Study metric:
Fubini–Study Geometry develops this projective geometry. Here the line element measures sensitivity along the encoded family.
Structural Properties
Section titled “Structural Properties”These properties explain how changes of coordinates, preparation, and readout affect sensitivity.
Reparameterization
Section titled “Reparameterization”If is smooth and locally invertible, then
QFI has units inverse to the square of the parameter. A numerical value is not meaningful until the parameter coordinate and units are named.
Additivity
Section titled “Additivity”For independently prepared state families,
Hence independent identical probes carry . This is the information-theoretic origin of the inverse-square-root precision scaling developed on the Standard Quantum Limit page.
Convexity
Section titled “Convexity”For parameter-independent mixing probabilities ,
Unrecorded classical mixing cannot improve sensitivity. If the weights themselves depend on the parameter, they carry classical information and the useful extended bound is
Data Processing
Section titled “Data Processing”For a parameter-independent quantum channel ,
Measurement is such a channel from a quantum state to a classical register, so this monotonicity contains as a special case. Noise after encoding cannot create information about if the noise mechanism itself has no parameter dependence.
If a device or measurement depends on , its dependence can add a new encoding pathway. It must be included in the physical model; it is not a counterexample to parameter-independent data processing.
Recorded Classical Flags
Section titled “Recorded Classical Flags”Suppose orthogonal flag states preserve which branch occurred:
Then the information decomposes exactly as
This formula is useful for heralding, erasure flags, and branch-resolved experiments. Throwing away the flag applies a channel and can only reduce the information.
From Information to a Variance Bound
Section titled “From Information to a Variance Bound”For a locally unbiased scalar estimator based on independent copies, the classical and quantum Cramér–Rao inequalities form the chain
Each inequality has its own attainability question. The first depends on the estimator, sample size, model regularity, and likelihood. The second depends on the measurement and operating point. Equality in both generally requires a measurement that extracts the QFI and an estimator operating in a regime where the classical bound is attainable.
Cramér–Rao Bounds develops the corresponding assumptions for biased, Bayesian, finite-sample, and multiparameter inference. QFI supplies a precision benchmark; an achieved error bar requires an estimator and data.
Multiparameter Quantum Fisher Matrix
Section titled “Multiparameter Quantum Fisher Matrix”For parameters , define one SLD for each tangent direction,
The SLD quantum Fisher information matrix is
For any real direction in parameter space,
is the scalar QFI for motion along that direction. A singular indicates a direction with no first-order statistical sensitivity. This need not imply local non-identifiability: a probability proportional to plus a positive constant is injective near zero despite its vanishing derivative there.
The formal SLD matrix bound is
under local-unbiasedness and regularity assumptions. Unlike the scalar case, one measurement need not attain all matrix directions simultaneously. The SLDs can encode incompatible optimal observables.
If Hermitian SLD operators can be chosen to commute, their common eigenbasis provides a sufficient locally optimal measurement. Merely commuting after compression to the occupied subspace is not sufficient: for a pure state that subspace is one-dimensional even when different tangent measurements are incompatible. A weaker mean-commutator condition,
characterizes equality of the SLD and Holevo bounds in regular finite-dimensional models, with asymptotic attainability under the usual independent-copy and collective-measurement assumptions (Ragy, Jarzyna, and Demkowicz-Dobrzański, 2016). When incompatibility remains, weighted scalar costs and the Holevo Cramér–Rao bound give the operational joint limit; optimizing each diagonal element of separately overstates what one common experiment can deliver.
Nuisance Parameters
Section titled “Nuisance Parameters”Partition the parameter vector into a target and nuisance parameters . Formally partition the QFI matrix as
When the relevant inverses and attainability assumptions hold, the Schur complement
is the information remaining about when must also be inferred. It is no larger than . Calibration drift, unknown contrast, loss, phase offsets, and background rates can therefore erase an apparent one-parameter advantage.
For a quantum model this Schur complement is an SLD-based local benchmark. It does not remove multiparameter measurement incompatibility; a complete claim must analyze the attainable cost for the joint model.
Channel Quantum Fisher Information
Section titled “Channel Quantum Fisher Information”Often the unknown parameter belongs to a channel , not to a state supplied in advance. A single-use, ancilla-assisted channel QFI can be defined by
The input probe and ancilla are independent of the unknown parameter. The supremum must also state any energy or dimension constraints; without an energy bound it may be infinite for bosonic channels. The optimization includes the probe and any retained ancilla. With many channel uses, parallel entanglement, sequential controls, adaptive operations, and error correction may change the attainable information. The QFI of one chosen output state is therefore not automatically the ultimate limit of the physical sensor.
Noise should be placed inside the channel before optimization. Purification and Kraus-representation methods can upper-bound the output QFI, while channel extension methods expose when an ancilla helps and when asymptotic scaling is limited to linear growth. Quantum Channels and Noise develops the completely positive maps used here.
Probe Number and Scaling Preview
Section titled “Probe Number and Scaling Preview”For independent equatorial qubits acquiring the same phase, additivity gives
For an ideal -qubit GHZ state under the collective generator
the pure-state variance formula gives
These equations compare ideal unitary state families. Converting them into an error law requires preparation and readout costs, interrogation time, losses, repetitions, a phase range, and an estimator. Standard Quantum Limit develops the independent-probe benchmark, Heisenberg Scaling treats the ideal quadratic-QFI regime and its limits, and Spin Squeezing connects an implemented collective-spin readout to entanglement criteria.
What Quantum Fisher Information Does Not Tell You
Section titled “What Quantum Fisher Information Does Not Tell You”QFI answers a sharply defined question:
How distinguishable are infinitesimally neighboring states under the best locally chosen allowed measurement?
It does not answer several other questions without additional analysis:
| Question | Additional object needed |
|---|---|
| Which detector should be built? | an attainable POVM or receiver model |
| Which parameter branch is correct? | prior range, global likelihood, or adaptive localization |
| What error occurs after 20 shots? | finite-sample estimator distribution or interval construction |
| Is a multiparameter matrix bound attainable? | compatibility and Holevo-bound analysis |
| Does postselection improve total performance? | success/failure likelihood and full resource count |
| Is the sensor better than a baseline? | matched task, resources, noise, and decision metric |
| Is the model calibrated? | validation data and nuisance-parameter treatment |
Large QFI is valuable evidence of local quantum sensitivity. It is not a synonym for accuracy, resolution, bandwidth, dynamic range, robustness, or verified quantum advantage.
Exercises
Section titled “Exercises”1. Locally optimal qubit phase measurement
Section titled “1. Locally optimal qubit phase measurement”For
compute and show that measuring at attains it.
Solution
The derivative is
Hence
and
For ,
At , and . Therefore
2. A commuting family is classical
Section titled “2. A commuting family is classical”For
find the SLD and verify .
Solution
Because and its derivative are diagonal, the SLD is diagonal:
Indeed,
Then
Computational-basis measurement produces the same Bernoulli Fisher information and is optimal.
3. Generator variance can overestimate mixed-state sensitivity
Section titled “3. Generator variance can overestimate mixed-state sensitivity”Let
and . Compare with the QFI of .
Solution
The state is , so it commutes with every generator and
Therefore and . But
so
The variance reflects classical uncertainty over generator eigenvalues, not coherent motion of the mixed state. This is why cannot be extended from pure states as an equality.
4. Optimize a dephasing-limited interrogation
Section titled “4. Optimize a dephasing-limited interrogation”Suppose one frequency interrogation has
and . Neglect dead time and assume , so the continuous approximation describes many independent shots. Find the optimal and total QFI.
Solution
The total information is
Differentiating gives
Thus
and
Any preparation or readout dead time changes the repetition count and shifts this optimum.
5. Erasure with a recorded flag
Section titled “5. Erasure with a recorded flag”A parameter-independent erasure occurs with probability . Successful outputs retain , while erased outputs become an orthogonal flag . Show that
Solution
The output is a flagged direct sum,
The weights are independent of , so their classical Fisher information is zero. The erasure branch is also independent of . The flagged-state decomposition therefore gives
Quoting QFI only per successful event would omit the resource cost of erased trials.
6. Parameter-dependent heralding probabilities
Section titled “6. Parameter-dependent heralding probabilities”Consider a flagged state
where is parameter independent. Compute its QFI.
Solution
The orthogonal flag preserves both branch probabilities, so the exact decomposition applies:
Since and a Bernoulli distribution has Fisher information
the result is
The success rate is itself data. Conditioning only on successes discards its information and can distort resource comparisons.
7. Qubit-sphere quantum Fisher matrix
Section titled “7. Qubit-sphere quantum Fisher matrix”For
show that
and diagnose joint attainability away from the poles.
Solution
For pure states, the QFI matrix is four times the real part of the quantum geometric tensor,
Direct differentiation gives
The imaginary part of the off-diagonal quantum geometric tensor is
It is nonzero away from the poles, signaling incompatible tangent directions: the measurements separately optimal for polar and azimuthal displacement cannot generally saturate both scalar SLD bounds on one copy. At the poles, is unidentifiable and the matrix is singular.
8. Local information versus global ambiguity
Section titled “8. Local information versus global ambiguity”An measurement on the equatorial phase state gives
Show that its Fisher information is locally one away from zero-probability points, but explain why the measurement cannot distinguish from globally.
Solution
The derivatives are
Therefore
The limit is also one as , but the score information defined by the positive-probability outcomes exactly at zero is zero. These are different quantities at this nonregular point; a limit does not restore the ordinary regular Cramér–Rao assumptions. However,
so the entire likelihood is invariant under sign reversal. The Fisher information correctly describes local curvature on either branch, but it does not encode the global two-fold ambiguity. A restricted prior, another measurement quadrature, or an adaptive protocol is needed.
9. A rank-changing boundary
Section titled “9. A rank-changing boundary”Let for . Compare the SLD QFI at zero, its nearby limit, and the Bures distance from .
Solution
At zero, , so the SLD formula gives . For ,
Since the squared fidelity with is ,
The Bures coefficient is one, whereas . Rank changes invalidate the fixed-rank identity at that point. The sign of also remains globally ambiguous.
References
Section titled “References”- F. Albarelli, J. F. Friel, and A. Datta, “Evaluating the Holevo Cramér–Rao bound for multiparameter quantum metrology,” Physical Review Letters 123, 200503 (2019), doi:10.1103/PhysRevLett.123.200503.
- S. L. Braunstein and C. M. Caves, “Statistical distance and the geometry of quantum states,” Physical Review Letters 72, 3439–3443 (1994), doi:10.1103/PhysRevLett.72.3439.
- R. Demkowicz-Dobrzański, J. Kołodyński, and M. Guţă, “The elusive Heisenberg limit in quantum-enhanced metrology,” Nature Communications 3, 1063 (2012), doi:10.1038/ncomms2067.
- B. M. Escher, R. L. de Matos Filho, and L. Davidovich, “General framework for estimating the ultimate precision limit in noisy quantum-enhanced metrology,” Nature Physics 7, 406–411 (2011), doi:10.1038/nphys1958.
- A. Fujiwara and H. Imai, “A fibre bundle over manifolds of quantum channels and its application to quantum statistics,” Journal of Physics A 41, 255304 (2008), doi:10.1088/1751-8113/41/25/255304.
- C. W. Helstrom, Quantum Detection and Estimation Theory, Academic Press (1976), doi:10.1016/C2013-0-10310-8.
- A. S. Holevo, Probabilistic and Statistical Aspects of Quantum Theory, 2nd ed., Edizioni della Normale (2011), doi:10.1007/978-88-7642-378-9.
- J. Liu, H. Yuan, X.-M. Lu, and X. Wang, “Quantum Fisher information matrix and multiparameter estimation,” Journal of Physics A 53, 023001 (2020), doi:10.1088/1751-8121/ab5d4d.
- K. Matsumoto, “A new approach to the Cramér–Rao-type bound of the pure-state model,” Journal of Physics A 35, 3111–3123 (2002), doi:10.1088/0305-4470/35/13/307.
- M. G. A. Paris, “Quantum estimation for quantum technology,” International Journal of Quantum Information 7, 125–137 (2009), doi:10.1142/S0219749909004839.
- D. Petz and C. Ghinea, “Introduction to quantum Fisher information,” in Quantum Probability and Related Topics, World Scientific, 261–281 (2011), arXiv:1008.2417.
- S. Ragy, M. Jarzyna, and R. Demkowicz-Dobrzański, “Compatibility in multiparameter quantum metrology,” Physical Review A 94, 052108 (2016), doi:10.1103/PhysRevA.94.052108.
- D. Šafránek, “Discontinuities of the quantum Fisher information and the Bures metric,” Physical Review A 95, 052320 (2017), doi:10.1103/PhysRevA.95.052320.