

Trotter–Suzuki Methods
Trotter–Suzuki methods approximate evolution under a sum of generators by an ordered product of evolutions under simpler pieces. In quantum simulation, their defining advantage is an unusually direct interface between a Hamiltonian decomposition
and a circuit made from implementable factors . Their defining limitation is equally important: noncommuting factors introduce an algorithmic error whose size depends on nested commutators, ordering, simulation time, formula order, and the output being requested.
A product formula is therefore not specified by saying “use Trotterization.” A reproducible method must state the Hamiltonian split, term ordering, formula, number of time segments, implementation of every exponential, accuracy metric, and convergence evidence. Higher formal order alone does not establish lower cost.
The operator derivation explains why the product converges. Here the question is how to choose and implement a finite product at a useful accuracy and cost. Hamiltonian Simulation Algorithms compares its query assumptions with other algorithm families.
Required background. Hamiltonian Simulation defines the access and output problem; the Trotter formula and Baker–Campbell–Hausdorff expansion explain commutator errors. The circuit model supplies the gate ordering used below.
Finite product approximations
Section titled “Finite product approximations”Consider a finite-dimensional, time-independent Hamiltonian with a declared decomposition
Assume that each term exponential can be implemented, either exactly in an ideal gate model or within a separately budgeted synthesis error. For total time and equal segments, define
An order- product-formula step has the general form
with real coefficients and an ordered term list . The full ideal approximation is
Here, “order ” means that the one-step defect is as under the required boundedness and domain assumptions. It does not specify the constant multiplying that power, the number of exponentials, or the compiled gate cost.
The ordered sequence, its coefficients, the implemented term exponentials, and the target error metric together determine the calculation.
Choose the error metric first
Section titled “Choose the error metric first”Several inequivalent guarantees occur in practice:
- Full-unitary error: in operator norm.
- Channel error: the induced unitary channels are close in diamond norm, which is already insensitive to a global phase on either unitary.
- State-specific error: the two evolved states are close for a declared input or input subspace.
- Observable error: a declared expectation value differs by at most .
- Spectral error: eigenphases or energy differences used by phase estimation have a declared bias.
A full-unitary bound implies state and bounded-observable guarantees. For a density operator , observable , exact unitary , and approximate unitary ,
The converse need not hold. A local observable can be accurate even when a worst-case bound on the entire many-body unitary is large.
From Product Identities to Circuits
Section titled “From Product Identities to Circuits”It is convenient to write
so every is anti-Hermitian and all exponentials below are unitary.
First order
Section titled “First order”For a declared ordering , a Lie–Trotter step is
The rightmost factor acts first. Reversing the written order gives a different finite-step approximation unless the relevant terms commute. Repeating the step gives global error at fixed total time.
First order is often useful when factors are cheap, coherent depth is tightly limited, or the split has small commutators. It is not automatically the best low-depth formula: a symmetric step can remove the leading error with modest additional structure.
Second order
Section titled “Second order”A symmetric, or Strang, step is
It is time symmetric:
Near , choose the analytic logarithm with . Time symmetry makes this logarithm odd in . Consistency fixes its linear term to , so the one-step defect begins at and the fixed-time global error is . The raw difference can still contain even powers; see Exercise 6.
The displayed step contains term exponentials after merging the two central half steps. Repetition permits another exact merge at each segment boundary. Thus, a compiler that preserves the symmetric structure can use
term exponentials before exploiting any further commutation or gate cancellation. Quoting is a valid unreduced count, but it is not the best count for the repeated circuit.
Higher even orders
Section titled “Higher even orders”Starting from , Suzuki’s recursive construction defines
The local defect is . Before boundary merging, every recursive level multiplies the number of lower-order modules by five. This rapid stage growth competes against the smaller number of required segments.
For , the middle coefficient satisfies
The circuit must therefore implement backward evolution under some terms. On a digital gate model this usually means changing rotation signs or using inverse gates. On an analog platform with irreversible controls, bounded amplitudes, or a dissipative semigroup, a negative coefficient may be unavailable or expensive. More generally, no real-coefficient splitting of generic noncommuting operators can attain order above two while keeping every time coefficient positive.
Local Error, Global Error, and Cost
Section titled “Local Error, Global Error, and Cost”Suppose a one-step bound has been established for sufficiently small :
Because both the exact and approximate steps are unitary, a telescoping sum gives
Within the step-size regime of that bound, it suffices to choose an integer
If the one-step estimate is established only for , also impose and . A leading asymptotic coefficient alone is not a finite-step certificate.
If one step uses term exponentials after merging, the primitive count is approximately
This pair of equations displays the real optimization problem. Increasing improves the power of , but usually increases , introduces larger coefficient magnitudes, and changes . A fourth-order formula is not intrinsically cheaper than a second-order one.
A two-term first-order bound
Section titled “A two-term first-order bound”For , the unitary integral representation yields
After segments,
The formula is exact at every step if . A bound depending only on would miss this decisive structure.
A two-term second-order bound
Section titled “A two-term second-order bound”For the -sandwiched formula
one convenient norm estimate is
Interchanging which term is sandwiched interchanges the coefficients attached to the two nested commutators. Thus even the two possible Strang orderings can have meaningfully different error constants.
General commutator scaling
Section titled “General commutator scaling”For a fixed order- formula, the leading coefficient can be bounded by a weighted sum of -fold nested commutators. Schematically,
where the nonnegative weights depend on the selected formula and ordering. A rigorous bound then has the form
within the theorem’s stated regime. The constant and the exact commutator sum must come from the chosen bound; the schematic definition is not a license to silently set them to one.
A norm-only estimate uses
repeatedly. It can replace structural zeros by a combinatorial number of nonzero terms and overestimate the required severely. Such a bound may be a valid certificate, but it should not be presented as a realistic resource prediction without comparison to tighter analysis or numerical evidence.
Decomposition, Grouping, and Ordering
Section titled “Decomposition, Grouping, and Ordering”The Hamiltonian split is part of the algorithm. Algebraically equivalent decompositions can have different commutator bounds and very different compiled costs.
Group commuting terms
Section titled “Group commuting terms”If terms in a set commute, define
Then
exactly, in any order within the group. Grouping can expose parallel layers and reduce the number of noncommuting blocks. It does not make the physical gates free: overlapping commuting Pauli rotations may still contend for the same qubits, and exponentiating a generic commuting sum can require a nontrivial basis change.
Order by both algebra and compilation
Section titled “Order by both algebra and compilation”At finite , changing the order changes the nested commutator coefficient. It can also change routing, basis-change cancellation, rotation merging, and parallel depth. A sensible ordering study therefore records at least two scores:
Minimizing one need not minimize the other. For electronic-structure Hamiltonians, term ordering has been observed to change finite-instance Trotter errors substantially even among formulas with identical formal order. The selected heuristic and any search budget should be reported, not hidden behind the final permutation.
Preserve exact cancellations
Section titled “Preserve exact cancellations”Before synthesizing individual rotations, simplify the symbolic product:
- merge adjacent exponentials of the same generator;
- commute disjoint operations into parallel layers;
- cancel inverse basis changes and parity networks when valid;
- retain parameter symbols until after merging equal rotations;
- distinguish an algebraic cancellation from one introduced only by an approximate compiler pass.
Compiling each segment independently and concatenating the results can miss boundary cancellations that are exact in .
Local Hamiltonians and Nearly Linear Scaling
Section titled “Local Hamiltonians and Nearly Linear Scaling”Locality changes the system-size dependence because most formal nested commutators vanish. Consider an open one-dimensional chain
Split the bonds into odd and even layers,
Terms commute within each layer because their supports are disjoint. A nested commutator of fixed depth has bounded spatial support, and only of its translations are nonzero. For a fixed order , a representative scaling is
where the hidden constant depends on the formula, interaction range, and local geometry. It is enough to take
Since each segment uses local gates at fixed , the gate count obeys
Choosing increasingly high even order while accounting for Suzuki’s stage growth gives nearly linear asymptotic scaling for finite-range lattice Hamiltonians, commonly summarized as in units with bounded local interaction strength and fixed accuracy conventions. That statement is not a guarantee that very high order wins at a finite problem size.
Higher-dimensional lattices
Section titled “Higher-dimensional lattices”On a finite-range interaction graph, edge coloring partitions local terms into sets of disjoint interactions. For a hypercubic nearest-neighbor lattice in dimensions with open boundaries, a -color construction gives disjoint bond layers. It also works with even periodic side lengths. Odd periodic cycles can require an extra layer: a ring of five sites cannot be edge-colored with two colors. The number of layers remains bounded for fixed degree, but the boundary conditions affect its exact value. Each layer contains gates but can have constant ideal depth when all disjoint gates are natively executable in parallel.
Gate count and depth must therefore be stated separately. If a fixed-order step has commuting-layer modules, then ideally
for an ideal bounded-degree architecture, before routing and control constraints. A device whose connectivity does not match the interaction graph can lose the depth advantage.
Local observables
Section titled “Local observables”Suppose the requested output is
for an observable supported on a fixed region. Under finite-range or suitably decaying interactions, only terms inside the observable’s effective light cone can influence it appreciably at finite time. A locality-aware product formula can omit operations outside a buffered causal region and use an error analysis tied directly to .
For fixed time and local accuracy, this can remove the dependence on the total system size once the system is larger than the required light cone. The cost still grows with time, interaction range, desired precision, and the support of . It also does not supply a full-unitary approximation for later use by an arbitrary algorithm. Preparing the initial reduced state on the retained region remains a separate task; spatial locality does not make an arbitrary correlated input cheap to prepare.
Worked Example: Transverse-Field Ising Chain
Section titled “Worked Example: Transverse-Field Ising Chain”For an open chain of qubits, take
with
All terms commute within , and all terms commute within . Consequently,
A second-order step is
The source of product-formula error is not the number of terms by itself, but their cross-commutator:
The elementary norm bound
makes the extensive first-order scaling explicit, although it need not be tight. If either or , the commutator vanishes and the split is exact.
Circuit anatomy
Section titled “Circuit anatomy”Define . A nearest-neighbor interaction rotation can be synthesized as
Each rotation is a single-qubit operation. Although all rotations commute, adjacent bonds share a qubit; on a conventional circuit scheduler they form odd- and even-bond sublayers. The rotations form one parallel layer.
Across symmetric steps, adjacent half steps at segment boundaries merge. The symbolic circuit therefore contains
rotations and
rotations, including the two half-angle boundary layers. A naive segment-by-segment count of rotations misses this exact reduction.
The ideal second-order error scales as at fixed , , , and . A practical study should verify that slope on small exactly solvable instances, then check the observable of interest as is doubled on the target workflow. Transverse-Field Ising Model explains the model’s phases and physical interpretation.
Pauli-String Exponentials
Section titled “Pauli-String Exponentials”After a qubit encoding, many applications produce
where each is a tensor product of Pauli operators. Since ,
For a weight- string, a standard synthesis performs local basis changes, computes the parity onto one qubit, applies , uncomputes the parity, and reverses the basis changes. On all-to-all connectivity, a simple ladder uses entangling gates. Hardware connectivity, native parity operations, ancilla availability, and neighboring strings can change that count substantially.
For the Hamiltonian coefficient , the rotation parameter in one first-order segment is
The factor of two in the physical angle follows from the convention . Confusing with produces a factor-of-two simulation error, not a small synthesis error.
Controlled evolution
Section titled “Controlled evolution”Phase estimation and some correlators require controlled evolution. A direct construction controls each term exponential, but need not control every gate inside it. For a term compiled as ,
On the control-zero branch, the unconditional basis changes cancel. The same principle can simplify parity networks or routing with an exact inverse. Known scalar phases of the term must still become the appropriate control phases. Thus controlled cost must be derived from the compiled construction, not obtained by controlling every gate blindly or reusing the uncontrolled count unchanged.
Randomized Product Formulas
Section titled “Randomized Product Formulas”Deterministic formulas use a fixed ordering in every segment. A randomized formula may sample a permutation for segment and apply
Randomization can cancel coherent contributions in expectation and supports stronger error bounds in important regimes. It also changes the object being analyzed. Averaging over sampled circuits gives the channel
which is generally not the unitary channel generated by one “average circuit.” A theorem about expected channel error does not imply that every sampled trajectory has the same error. One must report whether permutations are sampled once, independently by segment, or independently by experimental shot, and how randomization variance enters the estimator.
Randomly permuting every term is also distinct from qDRIFT, which samples individual Hamiltonian terms with probabilities proportional to their coefficient magnitudes. The two methods have different channels, complexity parameters, and guarantees.
Time-Dependent Hamiltonians
Section titled “Time-Dependent Hamiltonians”For
the target propagator is time ordered:
There are now at least two discretization problems:
- approximating the chronological variation of within each interval;
- splitting the noncommuting terms at the selected sample times.
A basic first-order step over is
Its error contains time-sampling contributions involving temporal variation and splitting contributions involving commutators. Replacing by a midpoint can improve quadrature accuracy under smoothness assumptions, but it does not by itself create an arbitrary-order time-dependent Suzuki formula. Higher-order constructions require correctly placed evaluation times or explicit time-ordered exponentials.
Useful bounds depend on quantities such as
and time-separated commutators
The sampling rule, smoothness assumptions, and oracle or control cost for evaluating must be stated. When has separated energy scales and is cheaply implementable, an interaction-picture, time-dependent product formula can replace a bound governed by with one that exploits the small perturbation and transformed commutators. This improvement is structural, not a generic property of midpoint sampling.
Product Formulas and Phase Estimation
Section titled “Product Formulas and Phase Estimation”If phase estimation uses a finite-step product formula, it resolves eigenphases of the implemented unitary
for a branch-dependent effective Hamiltonian
It does not directly return exact eigenvalues of . For a symmetric order- formula, the effective-Hamiltonian correction begins at order under suitable spectral and branch conditions. Energy bias can be state dependent, and energy differences may exhibit cancellations not visible in a full-unitary norm bound.
If
then every implemented eigenvalue lies within chordal distance of some exact eigenvalue. To see this, apply to a normalized eigenvector of . Since is normal, the residual norm bounds the distance to its spectrum. On the unit circle, the corresponding shortest angular displacement obeys
If a physical energy branch can be identified without phase wrapping, this gives the corresponding scale
Spectral proximity does not by itself identify eigenvectors or preserve an initial state’s weight in a particular nearly degenerate eigenspace. Moreover, phase estimation must use consistent controlled powers of the chosen unitary. Independently changing the Trotter step size for each requested power generally changes and needs a separate error analysis. Quantum Phase Estimation explains the additional resolution, overlap, and aliasing requirements.
Accuracy and implementation cost
Section titled “Accuracy and implementation cost”Separate the ideal splitting error from model reduction, finite encoding, gate synthesis, hardware noise, and measurement uncertainty. Bounds can be added only after conversion to a common output metric; a statistical interval also needs its confidence level. A rotation count omits routing, native gate decomposition, controls, fault correction, and repeated measurements.
Near-term experiments often depend most strongly on routed two-qubit depth and shots. Fault-tolerant estimates also depend on logical qubits, non-Clifford count and depth, and magic-state throughput. Resource Estimation Tools connects those circuit costs to an architecture.
Choosing a finite segment count under noise
Section titled “Choosing a finite segment count under noise”On an ideal computer, refinement reduces the asymptotic error bound, although the actual finite-step error need not decrease monotonically. On a noisy device, a coarse diagnostic model may be
where the first term represents algorithmic error and the second represents depth-proportional implementation error. Treating as continuous gives
This explains why “more Trotter steps” can worsen measured performance. The model is not universal: coherent gate errors, cancellation, drift, leakage, and mitigation can violate the linear term. It is a design diagnostic to be validated, not a substitute for device characterization.
Validation and Convergence
Section titled “Validation and Convergence”Formal order should be checked against the implemented workflow.
Exact small-instance benchmarks
Section titled “Exact small-instance benchmarks”For small Hilbert spaces, compute
The phase minimization is appropriate when the unitary is used only as an uncontrolled channel, because a global phase then has no operational effect. For controlled evolution or phase estimation, compare without that minimization: the relative phase between control branches is observable. Also compare state fidelity, conserved quantities, and the actual target observable. A commuting instance is a useful zero-error test but cannot measure convergence order.
Refinement studies
Section titled “Refinement studies”In the asymptotic regime,
for a generic order- formula. An observed order can be estimated from three successive refinements:
This estimate is meaningful only when the denominator is resolved and the same state preparation, compiler, measurement protocol, and noise treatment are used. Accidental cancellation can produce a temporarily higher slope.
If the leading model is credible, Richardson extrapolation gives
Extrapolation can reduce bias in an observable but does not prepare a more accurate quantum state. It can also amplify statistical uncertainty and fail when hardware noise changes with depth.
An exact one-qubit cost comparison
Section titled “An exact one-qubit cost comparison”For , , and , the Pauli identity gives the exact exponential directly. Compare first order, the -sandwiched second order, and its recursive fourth-order Suzuki composition. After merging adjacent equal generators, their rotation counts are respectively , , and .
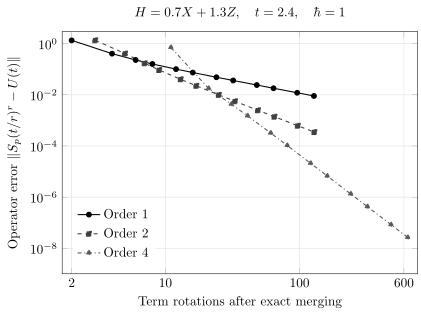
The points use and the operator norm without minimizing over global phase. Curves connect calculated points. Higher order gives a steeper asymptotic decrease, but its extra rotations matter at finite accuracy. These are ideal term rotations, before gate synthesis or noise; the one-qubit example is a convergence check, not a speedup demonstration.
Structural checks
Section titled “Structural checks”A good validation suite includes:
- exactness when all declared groups commute;
- unitarity of every ideal finite-step circuit;
- time-reversal symmetry for symmetric formulas;
- invariance under algebraically equivalent gate merging;
- convergence of the requested observable under ;
- comparison against exact diagonalization, tensor networks, free limits, or perturbative results where available;
- separate ideal-circuit and noisy-device results;
- at least one benchmark outside the parameter point used to tune ordering.
Trotter Evolution Notebook gives a compact finite-dimensional workflow for measuring first- and second-order slopes.
When a product formula is useful
Section titled “When a product formula is useful”Product formulas are attractive when term exponentials are compact, nested commutators sparse, or ancillas scarce. They can also exploit local observables and exact symbolic cancellations. Stringent precision, expensive controlled terms, or unavailable negative-time operations can favor a different method. Compare the same representation, input state, output, accuracy, and architecture: an oracle-query bound and a routed gate count measure different resources.
Exercises
Section titled “Exercises”1. Derive the global order
Section titled “1. Derive the global order”Assume and are unitary and
Prove the fixed-time bound for equal segments.
Solution
Use the identity
with and . Unitary invariance and submultiplicativity give
Therefore
The loss of one power relative to the local defect comes from accumulating steps.
2. Compare the two Strang orderings
Section titled “2. Compare the two Strang orderings”For , suppose
Using the bound on this page, which term should be placed on the outside if ?
Solution
For the -sandwiched formula, the displayed coefficient is
For the -sandwiched formula, the roles are interchanged:
If , placing on the outside gives the smaller bound because the large nested commutator receives coefficient rather than . This comparison concerns one bound; compiled gate cost can still reverse the practical choice.
3. Count merged second-order factors
Section titled “3. Count merged second-order factors”Show that repetitions of a reduced symmetric step with ordered terms contain term exponentials after merging only exact segment-boundary factors.
Solution
One reduced symmetric step contains exponentials. At each of the boundaries, its final is adjacent to the next step’s initial . They combine exactly into , removing one exponential from the count. Hence
Additional reductions require more information about commutation and the compiled realization.
4. Ising-chain commutator
Section titled “4. Ising-chain commutator”Derive
Solution
Only an acting on one endpoint of contributes. Using ,
and
The product of the two Hamiltonian coefficients is . Summing over bonds gives the result. Terms with commute.
5. Optimize a noisy proxy
Section titled “5. Optimize a noisy proxy”Minimize
for positive , , and continuous . Explain how an integer segment count should be selected.
Solution
Differentiate:
The stationary point is
Since
it is a minimum. In an actual circuit, evaluate the feasible integers near after compilation, because depth can change discontinuously through gate cancellation and routing. The proxy should then be checked against measured or characterized noise.
6. Which expansion is odd for a symmetric step?
Section titled “6. Which expansion is odd for a symmetric step?”Set , , and . Show that time symmetry does not remove all even powers from .
Solution
Multiplying the Pauli exponentials gives
The exact scalar coefficient is . Their difference is
Thus the raw defect contains a nonzero fourth-order term, alongside its leading third-order Pauli terms. The symmetry instead implies on the analytic branch near the identity. It is that logarithm whose even powers vanish.
7. Separate time sampling from splitting
Section titled “7. Separate time sampling from splitting”Suppose on one interval of width . Identify two errors in the approximation
What limits make each contribution vanish?
Solution
First, replacing the time-dependent generator throughout the interval by its left-endpoint value produces a time-sampling error. It vanishes when is constant on the interval and decreases under refinement when the required regularity bounds hold.
Second, splitting the frozen exponential into two factors produces a noncommutativity error. It vanishes when . A constant Hamiltonian removes the first error but not necessarily the second; commuting pieces remove the second but do not make a time-varying left-endpoint rule exact.
8. Allocate a spatial buffer and time-step error
Section titled “8. Allocate a spatial buffer and time-step error”Suppose a proven locality estimate bounds the error in an observable by
where is the spatial buffer and bounds unitary error on the retained region. Assume access to the correct initial reduced state. Allocate half of a tolerance to each term. Evaluate the required buffer for , , , , and , in lattice-spacing units.
Solution
A sufficient allocation is
Here , so choose ten lattice spacings, and . Errors in preparing the reduced state would consume an additional part of the tolerance. Numerical checks should vary both and the step count while using restrictions of the same global initial state. Convergence only in time step cannot reveal a spatial truncation bias, and this calculation does not approximate the full system’s unitary.
References
Section titled “References”- J. L. Bosse, A. M. Childs, C. Derby, F. M. Gambetta, A. Montanaro, and R. A. Santos, “Efficient and Practical Hamiltonian Simulation from Time-Dependent Product Formulas,” Nature Communications 16, 2673 (2025), doi:10.1038/s41467-025-57580-5.
- A. M. Childs, A. Ostrander, and Y. Su, “Faster Quantum Simulation by Randomization,” Quantum 3, 182 (2019), doi:10.22331/q-2019-09-02-182.
- A. M. Childs and Y. Su, “Nearly Optimal Lattice Simulation by Product Formulas,” Physical Review Letters 123, 050503 (2019), doi:10.1103/PhysRevLett.123.050503.
- A. M. Childs, Y. Su, M. C. Tran, N. Wiebe, and S. Zhu, “Theory of Trotter Error with Commutator Scaling,” Physical Review X 11, 011020 (2021), doi:10.1103/PhysRevX.11.011020.
- J. Huyghebaert and H. De Raedt, “Product Formula Methods for Time-Dependent Schrödinger Problems,” Journal of Physics A: Mathematical and General 23, 5777–5793 (1990), doi:10.1088/0305-4470/23/24/019.
- Q. Sheng, “Solving Linear Partial Differential Equations by Exponential Splitting,” IMA Journal of Numerical Analysis 9, 199–212 (1989), doi:10.1093/imanum/9.2.199.
- G. Strang, “On the Construction and Comparison of Difference Schemes,” SIAM Journal on Numerical Analysis 5, 506–517 (1968), doi:10.1137/0705041.
- M. Suzuki, “Generalized Trotter’s Formula and Systematic Approximants of Exponential Operators and Inner Derivations with Applications to Many-Body Problems,” Communications in Mathematical Physics 51, 183–190 (1976), doi:10.1007/BF01609348.
- M. Suzuki, “Fractal Decomposition of Exponential Operators with Applications to Many-Body Theories and Monte Carlo Simulations,” Physics Letters A 146, 319–323 (1990), doi:10.1016/0375-9601(90)90962-N.
- A. Tranter, P. J. Love, F. Mintert, and P. V. Coveney, “Ordering of Trotterization: Impact on Errors in Quantum Simulation of Electronic Structure,” Entropy 21, 1218 (2019), doi:10.3390/e21121218.
- H. F. Trotter, “On the Product of Semi-Groups of Operators,” Proceedings of the American Mathematical Society 10, 545–551 (1959), doi:10.2307/2033649.
- N. Wiebe, D. Berry, P. Høyer, and B. C. Sanders, “Higher Order Decompositions of Ordered Operator Exponentials,” Journal of Physics A: Mathematical and Theoretical 43, 065203 (2010), doi:10.1088/1751-8113/43/6/065203.