

Expectation Values
The expectation value of an observable is the first moment of its Born-rule probability distribution. Operationally, it is the average approached by many measurements on independently and identically prepared systems, provided the relevant expectation exists.
For a normalized pure state and a self-adjoint observable , the familiar operator formula is
For a density operator , the corresponding formula is
For an unbounded observable, this notation presupposes a finite absolute first spectral moment, ; the trace is then understood through the spectral integral. Without that condition, the mean need not exist.
These compact expressions are consequences of the Born rule. They do not say that a single measurement will return , nor that the system possesses this number before measurement. For the probability theory behind these averages, see Expectation Values in Probability, and for mixed-state matrix calculations, see Trace Rule for Expectation Values.
Required background. The Born Rule supplies the outcome distribution whose first moment is taken.
Helpful background. Spectral Decomposition supplies the observable’s spectral events; Expectation Values in Probability reviews discrete and continuous means.
Expected measurement outcome
Section titled “Expected measurement outcome”Let be the Born probability measure of in the state :
The expectation value is
when the integral is well defined. This definition makes the statistical content explicit: each possible outcome is weighted by its Born probability.
The notation suppresses the state. That shorthand is safe only when the state is clear from context. The same observable can have very different expectations in different states.
Repeated measurements and sample means
Section titled “Repeated measurements and sample means”Prepare independent systems in the same state , measure once on each, and denote the outcomes by . The empirical mean is
If the outcome distribution has a finite absolute first moment, the law of large numbers gives
with probability one as . Thus expectation values are testable ensemble predictions, not merely algebraic decorations on operators.
For finite , the sample mean fluctuates. If the variance is finite and the trials are independent, its standard deviation is
This statistical uncertainty is distinct from calibration errors, state-preparation drift, and detector systematics. The intrinsic spread is explained in Variance and Standard Deviation.
Expectation is not the most likely outcome
Section titled “Expectation is not the most likely outcome”The mean, mode, and median answer different questions:
- The expectation value is a probability-weighted average.
- A mode is an outcome with maximal probability or density.
- A median has probability at most strictly below it and at most strictly above it. An atom at the median can prevent an exact split.
They need not coincide. The expectation need not even be a possible individual outcome.
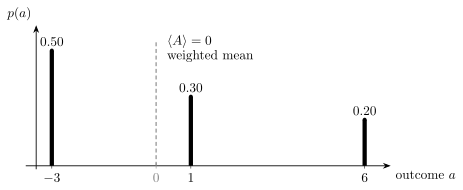
For outcomes , , and with probabilities , , and , the expectation is . It is neither an allowed outcome nor the most likely outcome, which is .
For this example,
The value zero summarizes the distribution’s first moment. It does not predict that any trial will produce zero.
Discrete outcomes
Section titled “Discrete outcomes”Suppose has a finite or countable spectral decomposition
where projects onto the full eigenspace with eigenvalue . The Born probability is
and the expectation is
For a pure state,
so
Degeneracy requires no extra probability rule: already includes every orthogonal state in the eigenspace. If a basis resolves a degeneracy label , then
For worked probability calculations, see Born Rule for Discrete Spectra.
Continuous outcomes
Section titled “Continuous outcomes”If the state-dependent spectral measure admits a density with respect to , then
For one-dimensional position in a pure state,
The density has inverse-outcome units, so the integrand times has the units of the observable. The full treatment of densities, atoms, and coordinate changes is at Born Rule for Continuous Spectra.
Mixed spectra
Section titled “Mixed spectra”An observable may have atomic weights at eigenvalues and an absolutely continuous density . Its expectation is
One must include both parts. Integrating only the continuum omits occupied bound-state components; summing only eigenvalues omits scattering outcomes. The measure expression
handles discrete, continuous, singular, and mixed spectral measures in one line.
Deriving the operator formula
Section titled “Deriving the operator formula”The spectral theorem represents a self-adjoint operator as
For a pure state, taking the quadratic form gives
This is exactly the probability-theory expectation. The operator expression and the weighted-outcome expression are not separate postulates; they are two representations of the same Born-rule statistic.
The practical spectral construction is developed at Spectral Decomposition.
Why the expectation is real
Section titled “Why the expectation is real”For , self-adjointness gives
Hence
In a finite-dimensional numerical calculation, a significant imaginary part usually signals that the matrix is not Hermitian, the state or inner-product convention was implemented incorrectly, or rounding errors are poorly controlled. For differential operators, bad boundary conditions or a domain mismatch can produce the same symptom.
Density operators and the trace rule
Section titled “Density operators and the trace rule”For a density operator with , the expectation is
If is bounded, is trace class and in any orthonormal basis ,
For unbounded , a finite absolute spectral moment does not by itself make a trace-class operator on the whole Hilbert space. The notation then denotes the spectral or quadratic-form expectation, rather than an arbitrary basis sum of operator-product entries.
If
then
The result depends only on , not on which ensemble decomposition is used to represent it. The cyclicity, basis independence, local-observable formulas, and unbounded-operator cautions of the trace expression are developed at Trace Rule for Expectation Values.
Linearity
Section titled “Linearity”Expectation is linear in the observable. For real and ,
whenever the required expectations and operator domains are well defined. The observables and need not commute. This is a statement about ensemble means, not about the existence of a joint sharp measurement.
Linearity does not imply factorization:
in general. Correlations, operator ordering, and noncommutativity matter for products.
Functions of an observable and moments
Section titled “Functions of an observable and moments”The functional calculus gives
Therefore
provided the expectation exists. Taking produces the moments
In particular,
Knowing only does not determine the distribution. Many different Born distributions share the same first moment.
Eigenstates and certainty
Section titled “Eigenstates and certainty”If
then
Every measurement of in that state returns in the ideal projective model.
The converse requires the zero-spread condition. Merely finding does not prove that the state is an eigenstate, even if happens to be an eigenvalue. Contributions above and below can average to the same number.
Bounds and the convex hull of outcomes
Section titled “Bounds and the convex hull of outcomes”If a bounded observable satisfies
then every state obeys
For a finite spectrum, the expectation is a convex combination of eigenvalues and lies in their convex hull. For a two-outcome observable with eigenvalues and ,
so the mean lies between the two outcomes. It need not equal either one.
These bounds are valuable sanity checks. A computed spin expectation outside the operator’s spectral interval is necessarily wrong.
Basis and matrix formulas
Section titled “Basis and matrix formulas”Choose an orthonormal basis and represent the normalized state by a column vector . Then
Under a unitary basis change,
The scalar is unchanged:
An expectation value is representation independent even though the state components and operator matrix change.
Example: a qubit observable
Section titled “Example: a qubit observable”Write a qubit state and Hermitian observable as
Using and gives
For and ,
The outcomes are and . Any expectation in is possible, even though values strictly between the endpoints are not single-shot outcomes.
Example: energy in a superposition
Section titled “Example: energy in a superposition”Let and
Then
Relative phases among the do not affect the energy probabilities because is diagonal in this basis. For an observable that is not diagonal in the energy basis,
and off-diagonal terms can make relative phases observable.
Wavefunction representations
Section titled “Wavefunction representations”In a position representation, a pure-state expectation is formally
For position,
For momentum in the standard coordinate representation,
For states in the relevant self-adjoint momentum domain, integration by parts with its boundary conditions ensures that the last expression is real. When only the weaker first-moment condition holds, use the spectral or quadratic-form definition instead of assuming a differentiable wavefunction. The page Expectation Values in Wave Mechanics explains coordinate-space calculations, integration by parts, radial measures, and numerical quadrature.
Existence and unbounded observables
Section titled “Existence and unbounded observables”Normalization of the state does not guarantee that every expectation is finite. The measure-theoretic expectation exists as a finite number when
For a pure state and unbounded , the operator expression is certainly defined when lies in the operator domain . The expectation can also be handled through the associated quadratic form under the appropriate weaker integrability condition. Domain claims should therefore accompany formal differential-operator manipulations.
Higher moments require stronger conditions. A state can have finite but infinite , so its mean exists while its variance does not.
Symmetry does not rescue a divergent mean
Section titled “Symmetry does not rescue a divergent mean”Consider the normalized even density
The positive and negative tails appear to cancel in a symmetric principal value, but
Therefore the ordinary expectation of is undefined, not zero. Assigning a value by symmetric cancellation confuses a Cauchy principal value with a Lebesgue expectation. This distinction matters whenever outcome distributions have heavy tails.
Generalized measurements
Section titled “Generalized measurements”For a discrete POVM with numerical outcomes and effects ,
Its expectation is
where
is the POVM’s first-moment operator. Different POVMs can share the same while having different full distributions and higher moments. Measuring the sharp observable is therefore not generally equivalent to performing the original POVM.
See POVMs: First Encounter for generalized measurement probabilities and effects.
Time dependence and classical-looking motion
Section titled “Time dependence and classical-looking motion”In the Schrödinger picture, both the state and an explicitly time-dependent observable may contribute to the evolution of an expectation. Under the usual domain assumptions,
This equation does not turn an ensemble mean into a classical trajectory, but for position and momentum it leads to equations resembling classical mechanics under suitable conditions. The interpretation and approximation limits are at Ehrenfest Theorem Overview.
Common pitfalls
Section titled “Common pitfalls”An average need not be an allowed outcome. The mean summarizes repeated trials; it is not generally what the next trial will report.
Normalize the state before taking the average. For a nonzero unnormalized vector, divide the quadratic form by the squared norm. Otherwise even the expectation of the identity is wrong.
Check tails before using symmetry. An odd integrand has zero integral only when the required integral exists. Symmetric principal-value cancellation does not define a finite statistical mean.
Exercises
Section titled “Exercises”1. A three-outcome observable
Section titled “1. A three-outcome observable”An observable has outcomes , , and with probabilities , , and . Compute its expectation. Is the expectation an allowed outcome?
Solution
The expectation is
Here the expectation happens to equal the allowed outcome . That coincidence does not imply that every measurement returns ; the other outcomes still have total probability .
2. Mean versus most likely result
Section titled “2. Mean versus most likely result”A two-outcome observable returns with probability and with probability . Find the mean and the mode. Explain why neither alone fully describes the experiment.
Solution
The mean is
while the unique mode is . The mean is not a possible outcome, and the mode omits the rare but large result . The full probability distribution is needed to predict all frequencies.
3. Matrix expectation and basis change
Section titled “3. Matrix expectation and basis change”Let
Compute . Why must the answer be real despite the complex matrix entries?
Solution
First,
Therefore
The imaginary terms cancel because . A simultaneous unitary change of the state components and operator matrix would leave this scalar unchanged.
4. Phase-sensitive qubit expectation
Section titled “4. Phase-sensitive qubit expectation”For
compute . Which relative phase gives the largest value at fixed ?
Solution
Because
the expectation is the sum of the two cross terms:
At fixed with , this is largest for modulo . The example shows that relative phase can affect an expectation when the observable is not diagonal in the preparation basis.
5. Expectation from symmetry
Section titled “5. Expectation from symmetry”Let be a normalized, even position density with a finite absolute first moment. Show that . Why is the integrability assumption essential?
Solution
Since , the function is odd. Absolute integrability permits the positive and negative halves to be combined legitimately:
Without , the two half-line integrals may diverge. A symmetric principal value can then vanish even though the ordinary expectation does not exist.
6. A normalized state with no position mean
Section titled “6. A normalized state with no position mean”Verify that
is normalized, and show that diverges.
Solution
Evenness gives
For the absolute first moment,
The integrand behaves as for large , so the integral diverges logarithmically. The probability law is normalized, but its position expectation is undefined.
7. Energy expectation and relative phase
Section titled “7. Energy expectation and relative phase”Let
where and . Find . Does it depend on ?
Solution
Orthogonality and diagonal action of give
It is independent of because the energy probabilities are both . The relative phase can still affect expectations of observables with nonzero off-diagonal matrix elements between and .
8. Statistical precision
Section titled “8. Statistical precision”An observable has standard deviation in a fixed state. Assuming independent preparations and negligible systematics, how many measurements are needed to make the standard deviation of the sample mean at most ?
Solution
The sample-mean standard deviation is
Requiring this to be at most gives
so . This quantifies statistical precision only; systematic errors do not generally decrease as .
References
Section titled “References”- P. Busch, P. J. Lahti, J.-P. Pellonpää, and K. Ylinen, Quantum Measurement, Springer, 2016, Chapters 3–5.
- P. A. M. Dirac, The Principles of Quantum Mechanics, 4th ed., Oxford University Press, 1958, Chapters II–III.
- B. C. Hall, Quantum Theory for Mathematicians, Springer, 2013, Chapters 7–10.
- M. Reed and B. Simon, Methods of Modern Mathematical Physics, Vol. I: Functional Analysis, revised and enlarged ed., Academic Press, 1980, Sections VII.1–VII.3 and VIII.3.
- J. J. Sakurai and J. Napolitano, Modern Quantum Mechanics, 3rd ed., Cambridge University Press, 2020, Chapters 1–2.
- R. Shankar, Principles of Quantum Mechanics, 2nd ed., Springer, 1994, Chapters 1 and 4.
- J. von Neumann, Mathematical Foundations of Quantum Mechanics, Princeton University Press, 1955, Chapters II–III.