

von Neumann Measurement Model
The von Neumann model describes a measurement interaction as unitary evolution of a system and a pointer. It explains how an apparatus records information and how ignoring that apparatus changes the reduced state. To obtain selective probabilities and states, it still uses the Born rule and conditioning for the pointer; it does not derive a unique observed result from unitarity alone.
Helpful background. Tensor products describe joint states, and the partial trace gives the state of the system when its pointer is ignored.
Discrete Correlation Model
Section titled “Discrete Correlation Model”Let be orthonormal eigenstates of the system observable being measured, and let be the ready state of the apparatus pointer. An ideal premeasurement unitary satisfies
where normalized, mutually orthogonal pointer states represent perfectly distinguishable outcomes. The initial system and pointer are assumed uncorrelated. Orthogonality is a sharp-readout idealization; partial overlaps are considered below.
By linearity, an input superposition evolves as
The result is not a product state. It is an entangled system-apparatus state, unless only one coefficient is nonzero.
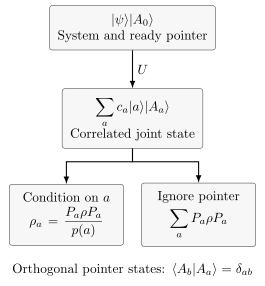
The von Neumann premeasurement step correlates system alternatives with pointer states . Reading the pointer gives a selective state; ignoring or tracing over the pointer gives the nonselective measurement channel.
Recovering Outcome Probabilities
Section titled “Recovering Outcome Probabilities”If the pointer states are orthonormal or effectively distinguishable,
then measuring the pointer in the basis gives outcome with probability
For a general density operator , the same ideal measurement is represented by projectors
and the probability is
Applying the Born rule to the pointer reproduces the system PVM probabilities when its states faithfully distinguish the alternatives. This is a consistency check of the apparatus model, not a derivation of the Born rule from unitary dynamics.
Selective Update from Reading the Pointer
Section titled “Selective Update from Reading the Pointer”Suppose the pointer is read and outcome is obtained. Conditioning the joint state on the pointer result gives the system state
This is the selective projective update. In the premeasurement picture, it is not applied before the apparatus interaction. It is the state assignment after the pointer record is known.
Nonselective Update from Ignoring the Pointer
Section titled “Nonselective Update from Ignoring the Pointer”If the pointer outcome is not read or not retained, the system state is obtained by tracing over the pointer. Starting from a pure input
the reduced system state is
If the pointer states are orthogonal, this becomes
For a general density operator, the unread ideal measurement channel is
Thus the nonselective update is reduced dynamics: the total system-apparatus state may evolve unitarily, while the system alone loses coherence in the measured basis.
Imperfect Pointers and Unsharp Measurements
Section titled “Imperfect Pointers and Unsharp Measurements”The ideal projective limit requires pointer states that are reliably distinguishable. If the pointer states have nonzero overlaps,
then the reduced state retains some coherence between and :
The measurement is then not fully projective. It may be better described as an unsharp measurement or a POVM, depending on how the pointer is read out. This is the operational meaning of finite resolution: if the apparatus cannot reliably separate alternatives, it cannot implement a sharp PVM.
Continuous Pointer Model
Section titled “Continuous Pointer Model”The textbook von Neumann model often uses a continuous pointer coordinate with conjugate momentum satisfying
Let the measured system observable be
During a short measurement interval, the interaction Hamiltonian is idealized as
Neglect the free system and pointer evolution during the pulse (the impulsive approximation), or work in a setting where they commute with this coupling and factor out. With
Hamiltonians at different pulse times commute, so the interaction unitary is
For an eigenstate and pointer wavefunction , this unitary shifts the pointer packet:
The displacement has the same units as . A superposition produces differently shifted pointer packets. For a real normalized Gaussian
is the standard deviation of the position probability density, not of the amplitude. Completing the square in the overlap integral gives
Thus a separation of one retains a coherence factor , while six leaves . The continuous position readout has measurement-operator density and . Its probability density is ; it is not the probability of an exact point outcome.
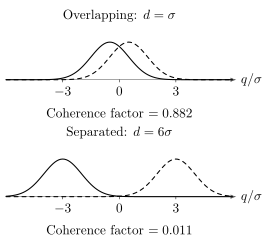
Both pointer packets have standard deviation . Increasing their center separation makes the readout clearer and reduces the unread system coherence by . The curves are probability densities; the coherence factor is an overlap of amplitudes.
Decoherence of Pointer States
Section titled “Decoherence of Pointer States”Macroscopic pointers are not isolated. They interact with many environmental degrees of freedom. A more realistic correlation chain is
After tracing over the environment, interference between different pointer alternatives is multiplied by environmental overlaps:
For macroscopic records, these overlaps are often extremely small on practical time scales. In a model whose interaction also preserves the relevant pointer alternatives, this suppresses observable interference between records. Small overlaps alone do not prove that an arbitrary pointer basis is dynamically stable.
This does not, by itself, settle every interpretation question about definite outcomes. It explains the suppression of interference in reduced descriptions and the robustness of pointer records.
Example: Stern–Gerlach as a Pointer Model
Section titled “Example: Stern–Gerlach as a Pointer Model”In a Stern–Gerlach measurement of spin along , the spin degree of freedom becomes correlated with spatial wavepackets. Schematically,
The spatial packet is the pointer. If and are well separated at the detection screen, reading the spot position approximately measures . If the packets overlap substantially, the measurement is not an ideal sharp spin measurement.
Exercises
Section titled “Exercises”- Suppose
and the apparatus unitary maps to and to . Write the final system-apparatus state.
Solution
By linearity,
For normalized input amplitudes, the state is entangled if both coefficients are nonzero and the pointer states are not proportional. Pointer states differing only by an overall phase represent the same physical ray and do not generate entanglement.
- For the state in Exercise 1, compute the reduced system density matrix when .
Solution
The reduced state is
If , the system is fully dephased in the basis. If , its magnitude is unchanged, although a complex phase of rotates the coherence. For the full original system state is recovered.
- In the continuous pointer model, why does large separation between pointer packets make the measurement closer to projective?
Solution
Large separation makes the shifted pointer wavefunctions nearly orthogonal. Orthogonal pointer states can be reliably distinguished and suppress off-diagonal reduced-system terms after the pointer is ignored. Overlapping pointer states give ambiguous readout and leave residual coherence, so the measurement is weaker or unsharp.
- Does the unitary premeasurement step by itself produce a selected outcome?
Solution
No. The premeasurement unitary produces a correlated superposition . A selective state is assigned only after conditioning on a pointer record. If the pointer is ignored, the system is described by a nonselective reduced state. Interpreting how a single definite outcome is selected is a foundations question beyond the unitary correlation step alone.
References
Section titled “References”- P. Busch and P. J. Lahti, “The standard model of quantum measurement theory: History and applications,” Foundations of Physics 26, 875–893 (1996). Author preprint.
- H. M. Wiseman and G. J. Milburn, Quantum Measurement and Control, Cambridge University Press (2010). Publisher.
- W. H. Zurek, “Decoherence, einselection, and the quantum origins of the classical,” Reviews of Modern Physics 75, 715–775 (2003). DOI.