

Position–Momentum Uncertainty
For a particle on the real line, every normalized state with finite position and momentum variances satisfies
This is the canonical position–momentum preparation uncertainty relation. It compares the root-mean-square widths of the position and momentum distributions assigned to the same state. It does not compare the calibration errors of two detectors, and it does not require position and momentum to be measured sequentially on one specimen.
The constant is state independent because the canonical commutator is central:
The same theorem is also a Fourier-analysis statement. Position and momentum wavefunctions are Fourier transforms, and a square-integrable function and its transform cannot both have arbitrarily small variance. Quantum mechanics turns those two mathematical widths into observable probability spreads.
The stronger covariance-sensitive form is
where is the symmetrized position–momentum covariance. An uncorrelated Gaussian saturates the product relation. A chirped Gaussian can saturate the stronger determinant relation while having .
Helpful background. General uncertainty relations supplies Cauchy–Schwarz and its equality condition; momentum-space representation explains the Fourier transform.
Position and Momentum on the Real Line
Section titled “Position and Momentum on the Real Line”The standard theorem applies to one Cartesian degree of freedom on the full line. The Hilbert space is
with normalized wavefunction
In the Schrödinger representation,
and
on , the square-integrable functions with square-integrable weak derivative. Position has domain . Finite second moments mean . The momentum-space wavefunction is
The inverse transform is
With this symmetric convention, Plancherel gives
Other Fourier conventions move factors of between the transform and the width inequality. The physical formula remains once momentum is identified as . The transform convention is explained in Fourier Transform Conventions.
The Two Probability Distributions
Section titled “The Two Probability Distributions”Position outcomes have density
with mean
and variance
Momentum outcomes have density
with mean
and variance
These are two representations of one state, not two independent probability models. The means and locate the packet in phase space; the uncertainty relation constrains its widths about those means.
A standard deviation is not a hard interval. In a non-Gaussian state, does not mean that every position outcome lies between and .
Derivation from the Canonical Commutator
Section titled “Derivation from the Canonical Commutator”The Robertson relation is
Set and . On a domain where the canonical relation is valid,
Normalization gives
Therefore
Unlike a generic commutator expectation, the right side cannot vanish in a normalized state. The identity operator is what makes this bound universal within the theorem’s domain.
The general Cauchy–Schwarz proof and equality criteria belong to General Uncertainty Relations. The algebraic and Weyl forms of the canonical relation belong to Canonical Commutation Relations.
Direct Wavefunction Derivation
Section titled “Direct Wavefunction Derivation”First take a Schwartz wavefunction, so all derivatives and boundary steps below are justified. A cutoff or common-core approximation then extends the inequality to every normalized ; the proof uses and , not their products.
Define the centered fluctuation vectors
and
Their norms are
Cauchy–Schwarz gives
Because
the term does not contribute, and
Let
Then
For a state with a vanishing boundary term, normalization gives
so
Since ,
Therefore
and Cauchy–Schwarz yields
The real part of is the symmetrized covariance . Retaining it gives the stronger determinant relation.
Why Fourier Duality Forces the Tradeoff
Section titled “Why Fourier Duality Forces the Tradeoff”Under the chosen transform, multiplication by in position space corresponds to differentiation in momentum space, while differentiation in position space corresponds to multiplication by :
and
Localization of requires a broad superposition of Fourier components. Conversely, concentrating near one momentum makes the position-space phase vary almost like a plane wave over a long region.
This is not merely a qualitative analogy. If the wave-number transform is written using , the variance theorem is
Multiplying by gives the physical momentum relation.
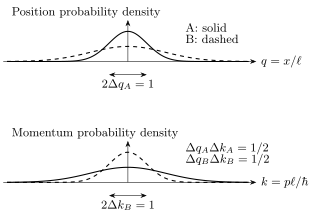
Two unchirped Gaussian states with zero means, drawn in dimensionless coordinates and . The solid state has ; the dashed state has . Both have product . Brackets span twice the marked standard deviation.
The general transform machinery is developed in Fourier Transform and Wave Packets.
Scaling Makes the Reciprocal Width Exact
Section titled “Scaling Makes the Reciprocal Width Exact”Let and define a rescaled normalized state
Its momentum wavefunction is
The means scale as and . After subtracting these means, direct substitution gives
and
Thus
Narrowing the position profile by a factor broadens the momentum profile by exactly . Scaling alone does not guarantee saturation; it preserves whatever uncertainty product the original shape had.
Equality Condition and the Gaussian
Section titled “Equality Condition and the Gaussian”For nonzero variances, Robertson equality requires the centered fluctuation vectors to be proportional with a purely imaginary coefficient. Write
Using gives the first-order equation
Its normalizable solutions are Gaussians. Writing
one obtains
where is an irrelevant global phase.
The probability density is
so
Fourier transformation gives a Gaussian centered at with
Hence
Translations , boosts , and a global phase do not affect the uncertainty product. Up to those changes and the width parameter, the uncorrelated Gaussian is the normalized equality state on the line.
The packet’s free evolution and its relation to coherent states belong to Minimum-Uncertainty Wave Packets and Gaussian Wave Packets.
Correlated Gaussians and the Stronger Relation
Section titled “Correlated Gaussians and the Stronger Relation”Consider the chirped Gaussian
where . Its position density is unchanged, but the quadratic phase correlates position and momentum. Direct differentiation gives
Therefore
and
These quantities satisfy
Thus every saturates Robertson–Schrödinger, while only saturates the simpler product relation. A state can be a minimum uncertainty state for the determinant bound without minimizing itself.
Physical Meaning of Narrowing a Packet
Section titled “Physical Meaning of Narrowing a Packet”A small means that repeated ideal position measurements on identically prepared systems have a distribution concentrated near in the root-mean-square sense. It does not mean that the wavefunction has compact support or that every outcome lies in an interval of width .
The inequality gives
This concerns spread about , not the size of . A packet can have a large mean momentum and a small momentum spread, or zero mean momentum and a large spread.
For a free particle of mass ,
Consequently,
Localization therefore carries a kinetic-energy cost. For an electron with and , the lower-bound contribution is about .
Idealized Sharp States Are Not Counterexamples
Section titled “Idealized Sharp States Are Not Counterexamples”Momentum plane waves
Section titled “Momentum plane waves”An ideal plane wave
has a sharp generalized momentum but is not square integrable on . It has no finite position variance. Normalized packets can approach a sharp momentum distribution only by spreading farther in position.
Position eigenkets
Section titled “Position eigenkets”An ideal position eigenket has wavefunction proportional to
It is a distribution rather than a vector in . Its Fourier amplitude has constant magnitude, so it does not define a normalizable finite-variance momentum distribution.
Infinite-variance states
Section titled “Infinite-variance states”Some normalized states have heavy tails and infinite or . The variance product is then not a useful finite diagnostic. This does not violate the theorem; it lies outside the finite-moment setting in which the numerical product is defined.
Higher Dimensions and Directional Pairs
Section titled “Higher Dimensions and Directional Pairs”For Cartesian components,
Therefore
for each matched component. Distinct components commute:
so this commutator supplies no positive lower bound for their product.
For real vectors and , define
Then
and
The bound depends only on the overlap of the two directions.
Preparation Uncertainty Is Not Error–Disturbance
Section titled “Preparation Uncertainty Is Not Error–Disturbance”The theorem can be tested by preparing many copies of . Position can be measured on one subensemble and momentum on another. Their empirical widths, after correcting for known detector effects, estimate and .
No first measurement is required to disturb a second measurement in this protocol. A sequential error–disturbance experiment asks different questions about an apparatus, its resolution, and its state-update map.
Heisenberg’s microscope was historically important for motivating operational limits, but the Kennard–Robertson variance inequality is a theorem about prepared-state distributions. The historical development belongs to Uncertainty: Historical Origin.
Domain and Boundary Conditions
Section titled “Domain and Boundary Conditions”Position and momentum are unbounded. A sufficient whole-line setting for the vector proof requires
and a representative for which the integration-by-parts boundary term
vanishes. Schwartz wavefunctions satisfy these conditions comfortably.
The vector proof needs the common operator domain , equivalently the common quadratic-form domain of and . The vanishing boundary term is automatic for the Schwartz calculation; the inequality extends to this full domain by approximation. Writing
as an ordinary operator expectation can require stronger product-domain conditions. The weak overlap proof avoids assuming that both and exist as Hilbert-space vectors.
Boundary conditions can alter the story:
- on a finite interval, self-adjoint momentum realizations depend on boundary conditions, and multiplication by may not preserve their domains;
- on a circle, a globally defined angle observable is not an ordinary Cartesian position operator;
- on a lattice or finite cyclic space, position and quasimomentum have discrete or periodic spectra and obey modified uncertainty relations;
- with gauge fields, canonical momentum and kinetic momentum are different observables.
State the configuration space and the actual observables before using the bound. Regular kinetic momentum also satisfies on the corresponding common domain; the distinction from canonical momentum matters especially for momentum-component commutators.
Common Pitfalls
Section titled “Common Pitfalls”Narrow position spread requires broad momentum spread, not large mean momentum. The kinetic-energy bound separates from for this reason.
A standard deviation is not a support interval. Even a Gaussian assigns nonzero probability outside . The theorem constrains second moments, not the largest possible outcomes.
A chirped Gaussian need not minimize the variance product. Its quadratic phase increases and introduces covariance while leaving unchanged. The determinant relation identifies the saturation correctly.
Exercises
Section titled “Exercises”Exercise 1: State-independent Robertson bound
Section titled “Exercise 1: State-independent Robertson bound”Starting from Robertson and , derive the position–momentum uncertainty relation. Identify exactly where normalization is used.
Solution
Robertson gives
The canonical relation implies
Normalization is used in
Hence
Exercise 2: The integration-by-parts constant
Section titled “Exercise 2: The integration-by-parts constant”Assume is normalized, differentiable, and decays sufficiently rapidly. Show that
Explain how this fixes the constant .
Solution
Let the integral be . Then
Integration by parts gives
Thus . The centered position–momentum overlap is , whose imaginary part is . Cauchy–Schwarz must therefore bound its modulus by at least .
Exercise 3: Gaussian saturation
Section titled “Exercise 3: Gaussian saturation”For
compute and without performing the full Fourier transform.
Solution
The density is a normal distribution of variance , so
Differentiate the wavefunction:
Therefore
Taking the norm gives
Thus and the product is .
Exercise 4: Fourier scaling
Section titled “Exercise 4: Fourier scaling”For , let
Derive and show how the two variances scale.
Solution
Substitute into the Fourier transform:
Changing variables in the second moments gives
and
Their product is unchanged.
Exercise 5: A chirped Gaussian
Section titled “Exercise 5: A chirped Gaussian”For the state defined in the text, verify
then compute and .
Solution
Differentiation gives
Applying yields the stated relation. Its squared norm is
The centered overlap is
Its real part is the symmetrized covariance:
Substitution verifies saturation of the determinant relation.
Exercise 6: Localization energy scale
Section titled “Exercise 6: Localization energy scale”For a free particle with , show that
Estimate the bound for an electron localized to .
Solution
Since ,
The uncertainty relation gives
so
Using and gives
Exercise 7: Directional uncertainty in three dimensions
Section titled “Exercise 7: Directional uncertainty in three dimensions”Let and be unit vectors. Derive
What does Robertson give when the directions are orthogonal?
Solution
Using ,
Robertson gives the stated bound. If the directions are orthogonal, the commutator vanishes and this particular relation gives only the trivial lower bound zero. It does not require either variance to vanish.
Exercise 8: Why the boundary term matters
Section titled “Exercise 8: Why the boundary term matters”Repeat the integration-by-parts step on an interval . Show that
Explain why the whole-line proof cannot simply be copied to arbitrary boundary conditions. Check the constant wavefunction with periodic momentum boundary conditions.
Solution
The calculation is identical except that the endpoints are finite:
Normalization makes the last integral one, yielding the stated result. The endpoint contribution need not vanish for periodic or other self-adjoint boundary conditions. In addition, multiplication by may not preserve the domain of the chosen momentum operator. For , , , and , so . The boundary contribution is exactly one, giving , not . Multiplication by spoils the periodic endpoint condition, so the formal cannot be applied to this vector as a product identity. There is no contradiction with the real-line theorem.
References
Section titled “References”- G. B. Folland and A. Sitaram, “The Uncertainty Principle: A Mathematical Survey,” Journal of Fourier Analysis and Applications 3, 207–238 (1997). DOI.
- B. C. Hall, Quantum Theory for Mathematicians, Springer, 2013.
- E. H. Kennard, “Zur Quantenmechanik einfacher Bewegungstypen,” Zeitschrift für Physik 44, 326–352 (1927). DOI.